Balancing a ball on a surface is a classic control problem that involves detecting the ball’s position in real time and adjusting the platform’s orientation accordingly.
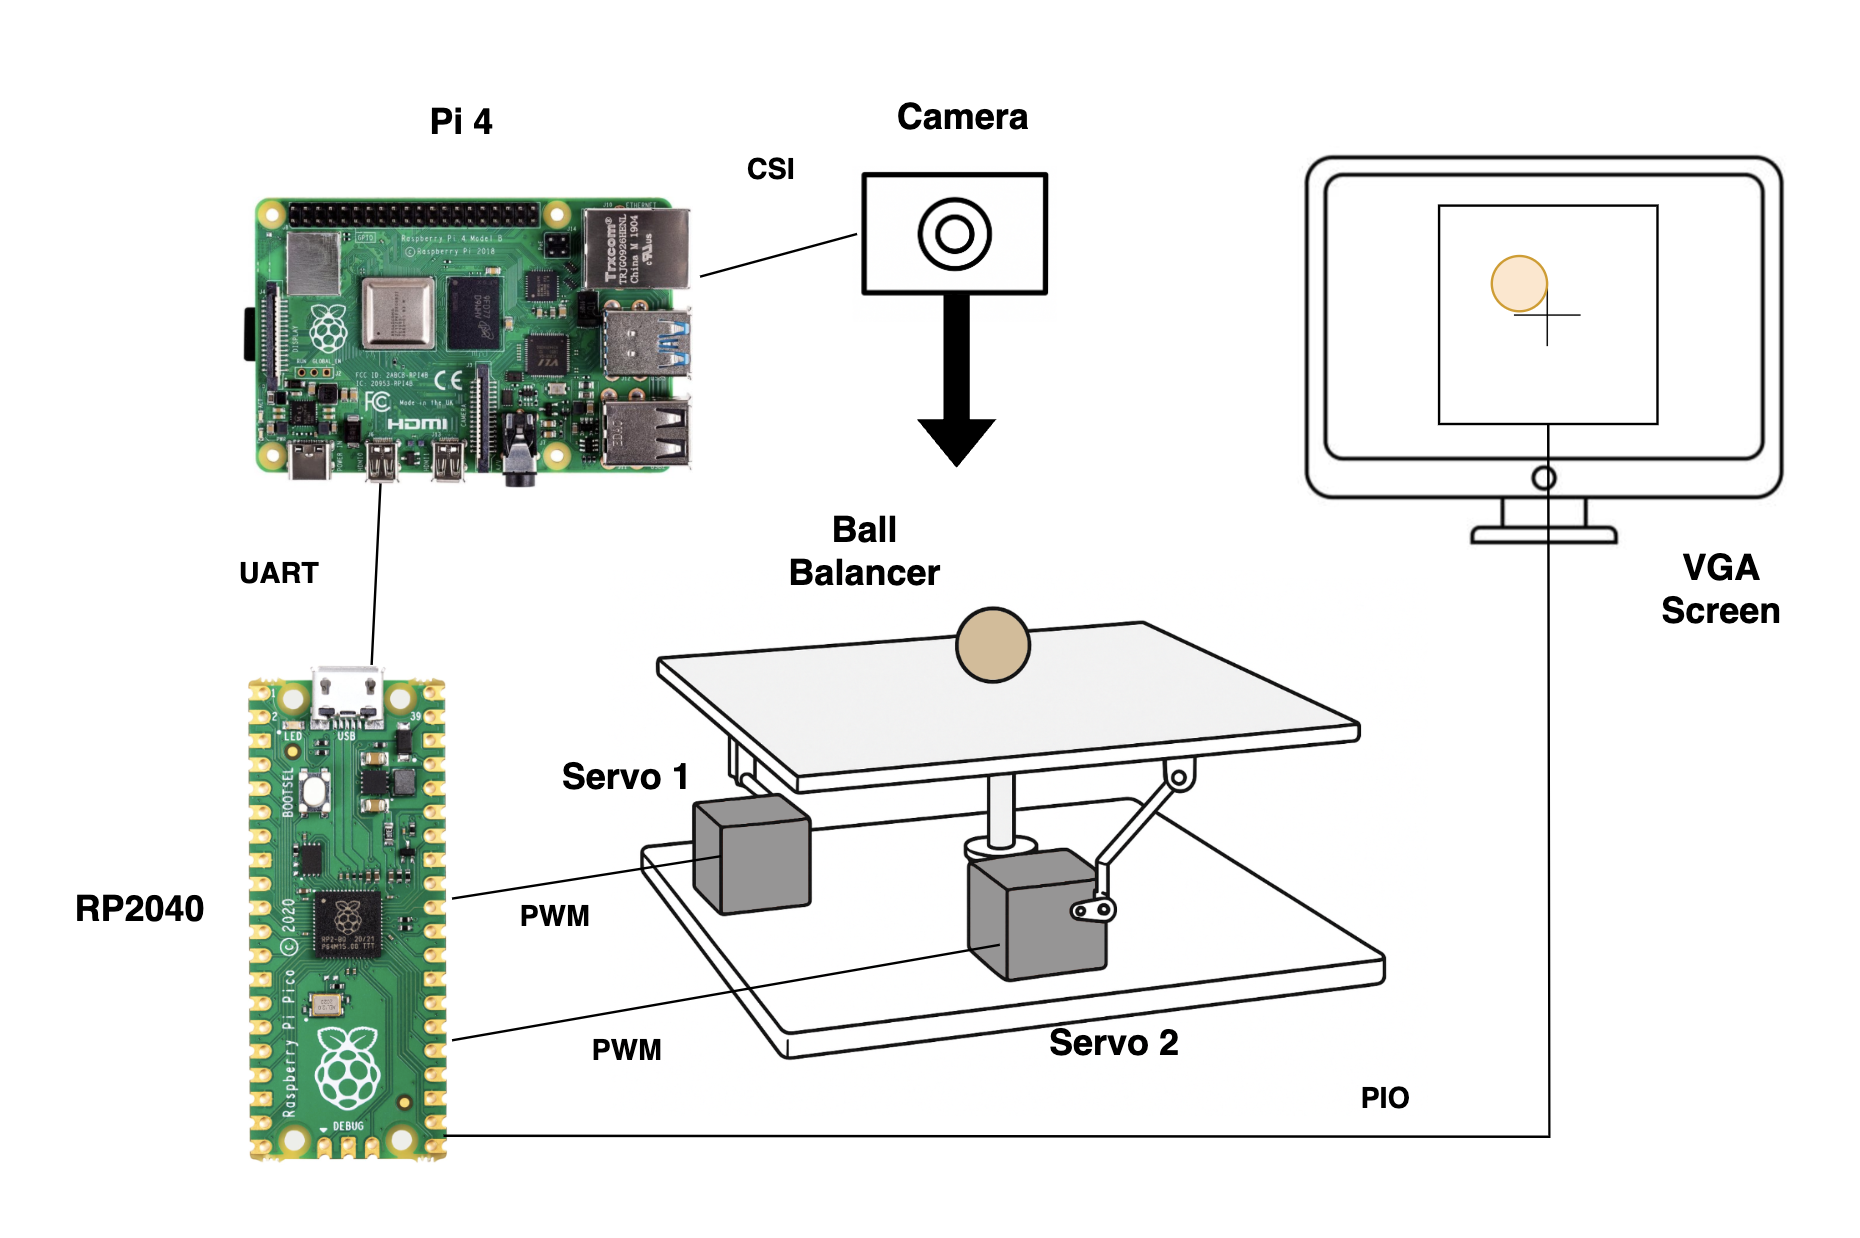
In this project, we built a two-degree-of-freedom ball balancing system using a Raspberry Pi 4, RP2040 microcontroller, servo motors, and a custom platform made from acrylic and 3D-printed parts.
The Pi Camera captures the ball’s position in real time, and the Raspberry Pi uses a computer vision algorithm to track the ball’s movement. The position data is then sent to the RP2040 through UART. The microcontroller runs a PID control algorithm that calculates the servo angles needed to tilt the platform and stabilize the ball. The ball’s position is also displayed in real time on a VGA screen as visual feedback. By isolating the x and y directions, we successfully balanced a 1-inch diameter ball on the platform.
Github: Ball Balancer